Hackathon build, 2026 / Flagship
Greenlight
A robot arm you drive in the browser, six different ways, through one motion pipeline.
- Role
- Lead developer
- Type
- Hackathon build, 2026
- Status
- Live
- Problem
Vantage Robotics tests every software change on a real arm, which is slow, risky and expensive. A motion change should be provable before hardware is involved at all.
- What we built
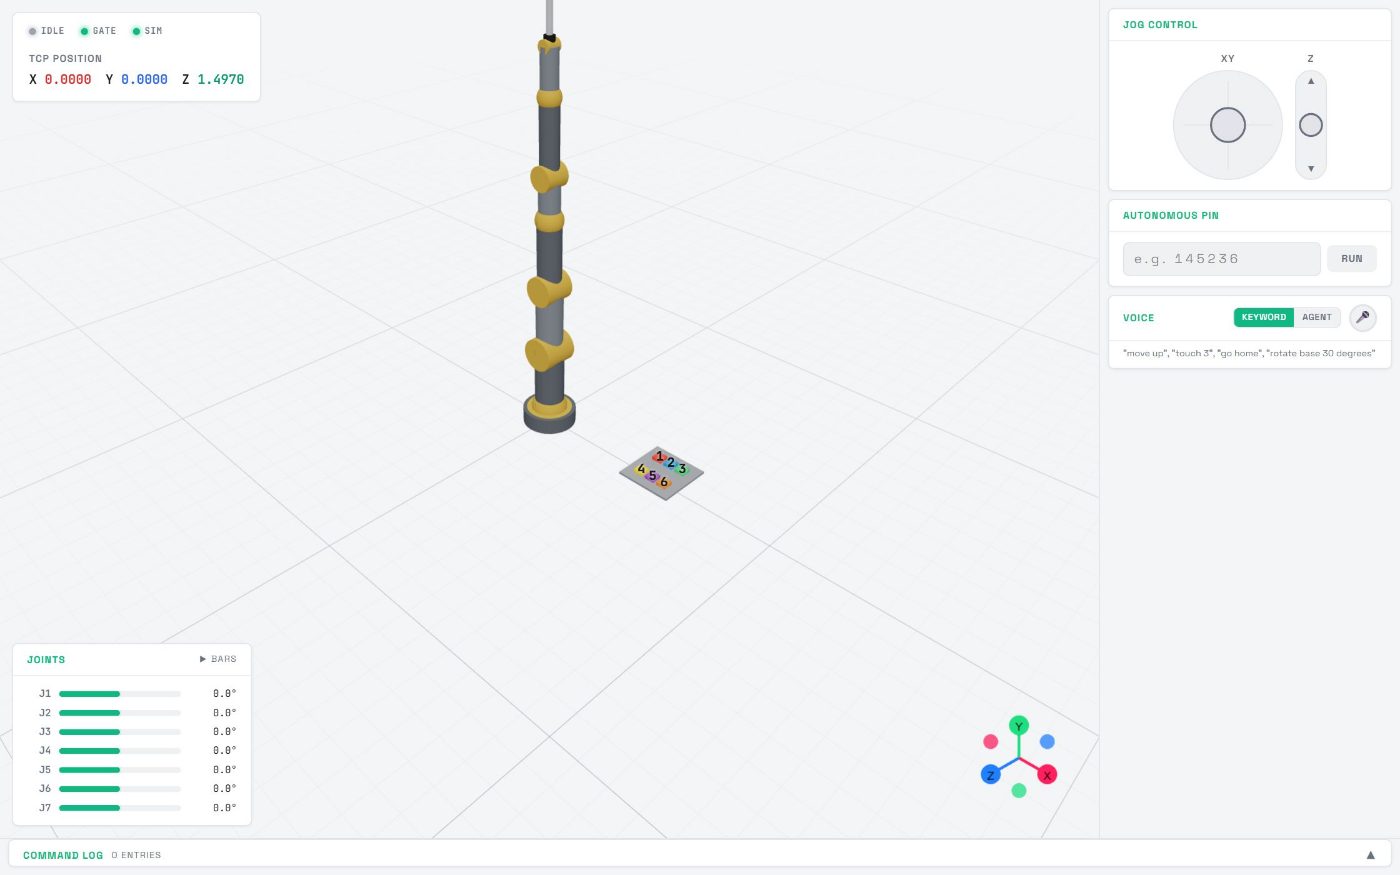
Six input methods, joystick, keyboard, voice keyword, voice agent, autonomous PIN entry and agentic natural language, all resolve to the same MotionCommand and run through one pipeline: an inverse-kinematics planner, a safety gate that validates the move, then an executor that animates it. One pipeline triggered six ways rather than six features bolted together, which is what stops any path from skipping the gate.
- My part
I wrote the software: forward and inverse kinematics, the safety gate, the planner and executor, and every input path from the joystick to agentic voice control. A teammate drew the electrical schematic.
- How it works
- 1Six inputs: joystick, keyboard, voice keyword, voice agent, PIN entry, natural language
- 2One MotionCommand
- 3Inverse-kinematics planner
- 4Safety gate validates the move
- 5Executor animates the arm
- Result
Built for the IUT Techathon and deployed, drivable in a browser with no hardware in the loop, alongside a Wokwi hardware simulation.
- Stack
Next.js, Three.js, TypeScript, Zustand, Gemini API